Icon

4D Imaging High-Resolution Radar, Explained.

October 4, 2026
Read Blog

By Shlomit Hacohen

TL;DR Read this in 30 seconds
  • Four measurements, one sensor: 4D imaging radar measures range, relative velocity (Doppler), horizontal angle (azimuth), and vertical angle (elevation) for every detection. Elevation is the dimension conventional automotive radar was missing.
  • Height changes the decision: With elevation, radar can tell an overhead bridge or sign gantry from a stopped vehicle in the lane, and a tire on the road from a guardrail beside it.
  • Channel count sets image quality: A conventional 3 Tx x 4 Rx radar has 12 virtual channels. Arbe’s 48 Tx x 48 Rx architecture delivers 2,304, which is what turns radar returns into a detailed 4D point cloud.
  • LiDAR-comparable performance, much more affordable: Arbe’s HD radar delivers performance comparable to LiDAR at a much more affordable cost, which can lower overall sensor suite costs while improving system redundancy.
  • All-weather by physics: Radar works in rain, fog, darkness, glare, and snow, the conditions where optical sensors degrade.
  • Built for eyes-off driving: At 130 km/h a vehicle covers 36 meters every second. Arbe’s ultra-HD radar achieves point cloud detections at over 300 meters and minimizes false alarms, giving Level 3 systems the time and detail to act.
  • On the road to series production: Hirain’s imaging radar, powered by Arbe’s chipset, was selected by one of the world’s largest automotive groups for a Level 3 program across multiple brands. Arbe also combines its radar with NVIDIA accelerated computing for AI-based perception.

TL;DR

  • Four measurements, one sensor: 4D imaging radar measures range, relative velocity (Doppler), horizontal angle (azimuth), and vertical angle (elevation) for every detection. Elevation is the dimension conventional automotive radar was missing.
  • Height changes the decision: With elevation, radar can tell an overhead bridge or sign gantry from a stopped vehicle in the lane, and a tire on the road from a guardrail beside it.
  • Channel count sets image quality: A conventional 3 Tx x 4 Rx radar has 12 virtual channels. Arbe’s 48 Tx x 48 Rx architecture delivers 2,304, which is what turns radar returns into a detailed 4D point cloud.
  • LiDAR-comparable performance, much more affordable: Arbe’s HD radar delivers performance comparable to LiDAR at a much more affordable cost, which can lower overall sensor suite costs while improving system redundancy.
  • All-weather by physics: Radar works in rain, fog, darkness, glare, and snow, the conditions where optical sensors degrade.
  • Built for eyes-off driving: At 130 km/h a vehicle covers 36 meters every second. Arbe’s ultra-HD radar achieves point cloud detections at over 300 meters and minimizes false alarms, giving Level 3 systems the time and detail to act.
  • On the road to series production: Hirain’s imaging radar, powered by Arbe’s chipset, was selected by one of the world’s largest automotive groups for a Level 3 program across multiple brands. Arbe also combines its radar with NVIDIA accelerated computing for AI-based perception.

What Is 4D Imaging Radar? 

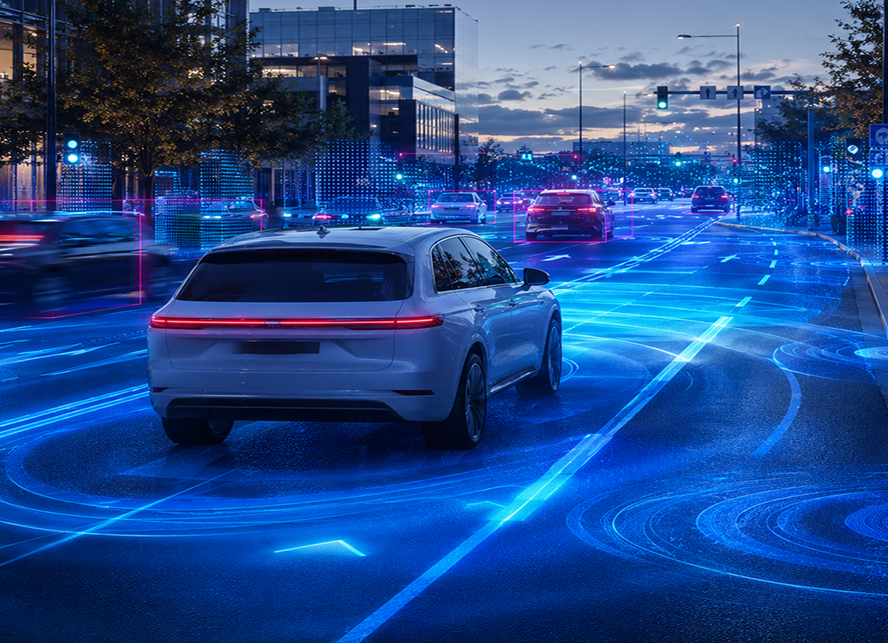
4D imaging radar adds the dimension conventional radar was missing: height.

Radar has been on cars for decades. It powers adaptive cruise control, blind spot detection, and automatic emergency braking. But conventional automotive radar was designed to answer a narrow question: is something ahead, how far, and how fast is it moving?

Eyes-off driving asks a much harder question. What exactly is in the scene, where does each object sit in three dimensions, and which of them matters right now? Answering that takes a different class of sensor. That sensor is 4D imaging radar.

What the “4D” in 4D imaging radar means

For every reflection it detects, a 4D imaging radar measures four things:

  • Range: how far away the object is.
  • Relative velocity (Doppler): how fast it is moving toward or away from the vehicle, measured directly in every frame rather than estimated over time.
  • Azimuth: its horizontal position, left to right.
  • Elevation: its vertical position, from road level up.

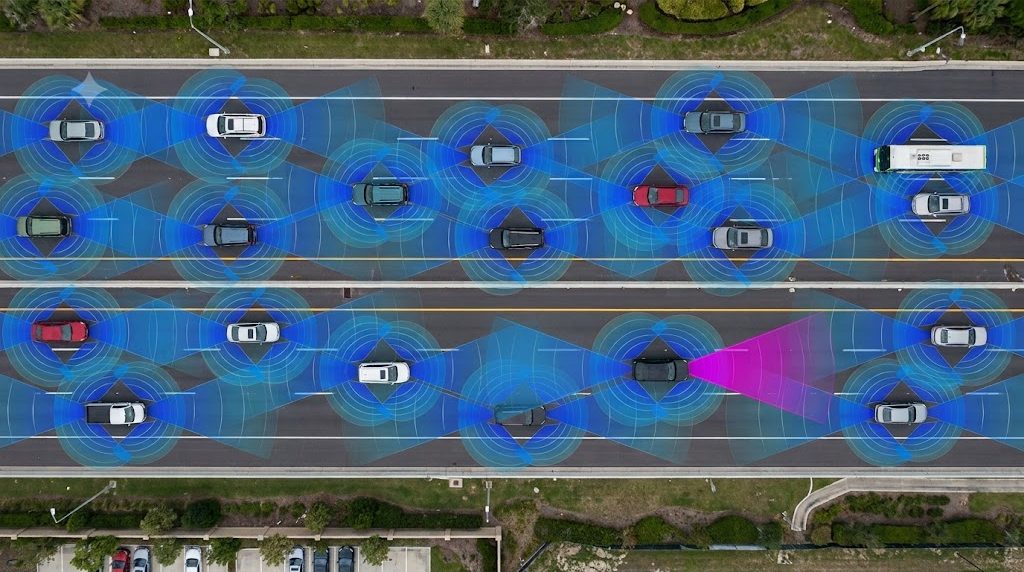
Conventional radar measures the first three, often with coarse angular detail. Adding elevation, at high resolution, is what makes it “imaging” radar: the output is no longer a short list of targets but a dense point cloud that describes the shape and position of everything in the field of view.

4D imaging radar vs. conventional automotive radar

Feature

Conventional automotive radar

4D imaging radar

Measurements per detection

Range, velocity, azimuth

Range, velocity, azimuth, and elevation

Typical array

3 Tx x 4 Rx = 12 virtual channels

Arbe: 48 Tx x 48 Rx = 2,304 virtual channels

Output

A handful of targets per object

Hundreds of detections per object in a dense point cloud

Height awareness

Little or none

Separates overhead structures from objects on the road

Small objects next to large ones

Often merged into one target

Resolved as separate objects

Main role

Driver assistance features

A primary perception sensor for autonomy


Why channel count determines image quality

A radar’s virtual channel count is the number of transmit channels multiplied by the number of receive channels. Each virtual channel adds another spatial observation of the scene. More channels mean finer angular resolution, cleaner data with fewer “ghost” reflections, and more confidence in where each return came from.

That is why Arbe built its radar around a massive channel array. Arbe’s chipset combines 48 transmit and 48 receive channels to create 2,304 virtual channels. In the Phoenix radar, that delivers angular resolution of 0.7 degrees in azimuth and 0.9 degrees in elevation across a 120 by 30 degree field of view, at 20 frames per second.

The historic barrier to arrays this large was processing. Thousands of channels generate raw data at roughly 3 terabits per second, more than conventional automotive processors can handle. Arbe solved this with a dedicated radar processor designed alongside its RF chips, so the full array is processed in real time inside the vehicle. For a deeper look, read Do You Need a High Channel Count Radar?

What 4D imaging radar sees that conventional radar misses

Resolution is easiest to understand through the scenarios it solves:

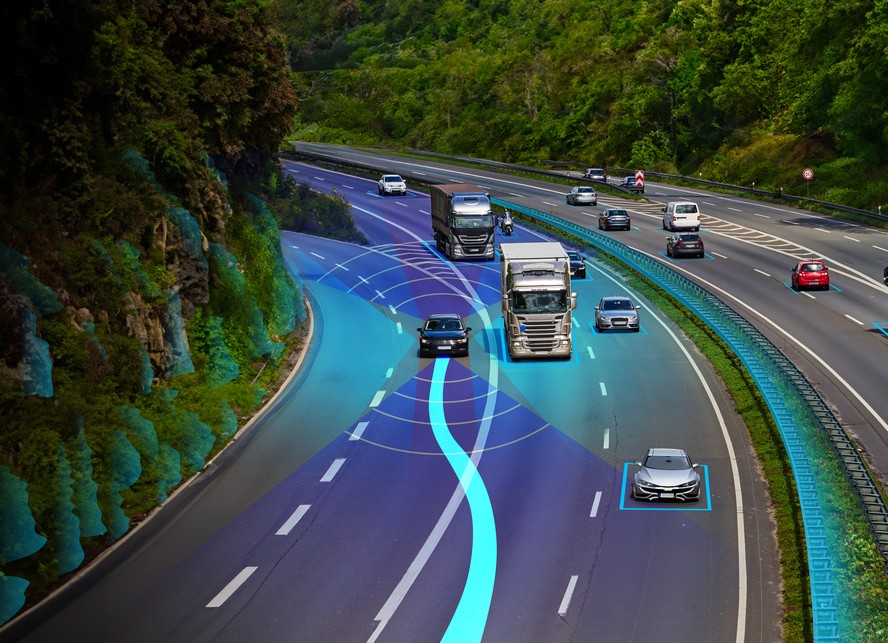
  • A bridge or a stopped car? A metal gantry over the highway and a stalled vehicle in the lane can return similar signals. Without elevation, radar either brakes for both or ignores both. 4D imaging radar measures height, so it can tell which one the vehicle can drive under.
  • Lost cargo beside a guardrail. A tire lying next to a guardrail at highway speed is a small, weak reflection next to a long, strong one. High dynamic range and fine resolution let 4D imaging radar separate the two and flag the tire as a hazard in the lane.
  • A child next to a bus. A large vehicle’s strong reflection can mask a small object beside it. Hundreds of detections per object let the radar resolve both, even when the smaller one is partly hidden.
  • Stationary objects. Conventional radar often filters out stationary returns to avoid false alarms, which can mean missing a stopped vehicle. Fine resolution and direct Doppler measurement let 4D imaging radar keep stationary objects in the picture without flooding the system with false alarms.

And because radar uses radio waves rather than light, it keeps performing in rain, fog, darkness, glare, and snow, where cameras and LiDAR lose visibility.

Why eyes-off driving depends on it

At Level 3, the vehicle drives itself within defined conditions, and the automaker takes responsibility while the system is active. That raises the bar for perception from “usually right” to “provably reliable.”

Speed makes the challenge concrete. At 130 km/h, a vehicle covers 36 meters every second. To brake smoothly or change lanes safely, the system needs to detect and classify hazards at around 300 meters. Conventional radar typically detects small objects such as pedestrians only up to about 80 meters, which leaves 2 to 3 seconds to react. That is not enough for eyes-off operation at highway speed.

4D imaging radar closes that gap with long range, fine resolution, and consistent performance in all weather and lighting. It also minimizes false alarms, which matters just as much: every phantom braking event or unnecessary takeover request erodes the driver’s trust in the system. Learn more about how Arbe radar enables eyes-off driving and why HD radar is key to true highway autonomy.

From point cloud to perception

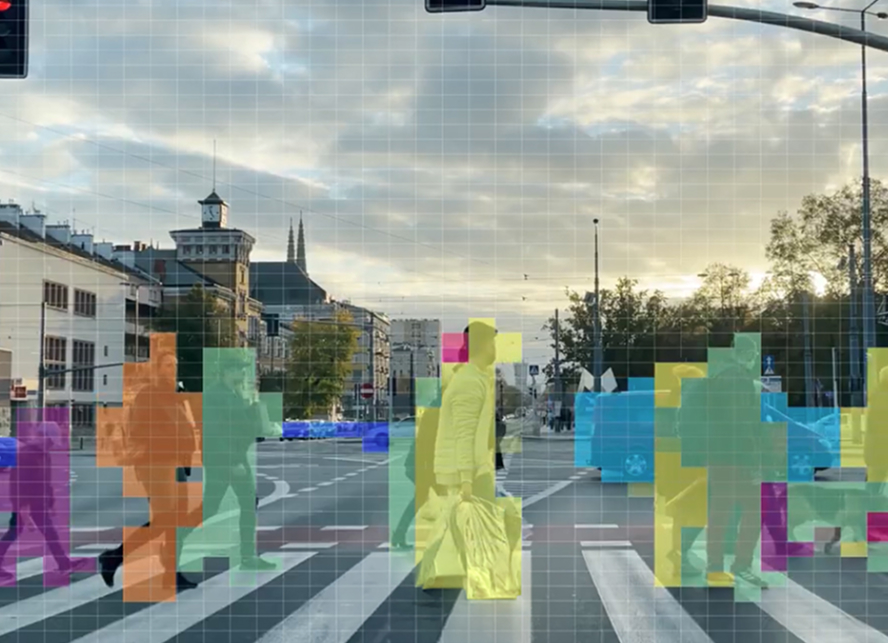
A dense 4D point cloud is only valuable if the vehicle’s AI can use it. Arbe processes radar data at the sensor and delivers structured, AI-ready output, including formats such as occupancy grids and bird’s-eye-view representations, to the vehicle’s central compute. This gives perception teams detailed radar evidence they can fuse with camera and LiDAR data, without overloading the system. See AI-ready radar perception.

From demo to series production

4D imaging radar is moving from evaluation into production programs. In September 2026, Hirain and Arbe announced that one of the world’s largest automotive groups selected Hirain’s imaging radar, powered by Arbe’s ultra-high-resolution radar chipset, “for a Level 3 automated driving passenger vehicle program in China, across multiple brands under the group.” Series-production radar deliveries are scheduled to begin in Q4 2027, ahead of vehicle start of production. Read the announcement.

At CES 2026, Arbe announced it is “combining Arbe’s leading radar technology, with NVIDIA accelerated computing, creating an advanced platform for AI-based perception for hands-off and eyes-off driving.” Arbe’s high-resolution radar data is processed on the NVIDIA DRIVE AGX Orin in-vehicle computing platform. Read the announcement.

Ready for the road ahead

4D imaging radar turns radar from a supporting sensor into a core layer of the perception stack. By adding elevation, resolving small objects at long range, and working in every condition, it gives automakers the evidence they need to move from driver assistance to certified eyes-off driving.

Discover what 4D imaging radar can do for your autonomy program.

Connect to learn more
When Does Radar Become a Perception Sensor?
September 5, 2026

When Does Radar Become a Perception Sensor?

Do You Need a High Channel Count Radar?
August 5, 2026

Do You Need a High Channel Count Radar?

Navigating the Noise
July 5, 2026

Navigating the Noise

Physical AI’s Real Bottleneck Is Perception
June 8, 2026

Physical AI’s Real Bottleneck Is Perception

Why ‘Good Enough’ Detection Fails in the Mine and on the Farm
April 27, 2026

Why ‘Good Enough’ Detection Fails in the Mine and on the Farm

Level 3 Autonomy: The Next Leap in Driving Confidence
November 10, 2025

Level 3 Autonomy: The Next Leap in Driving Confidence