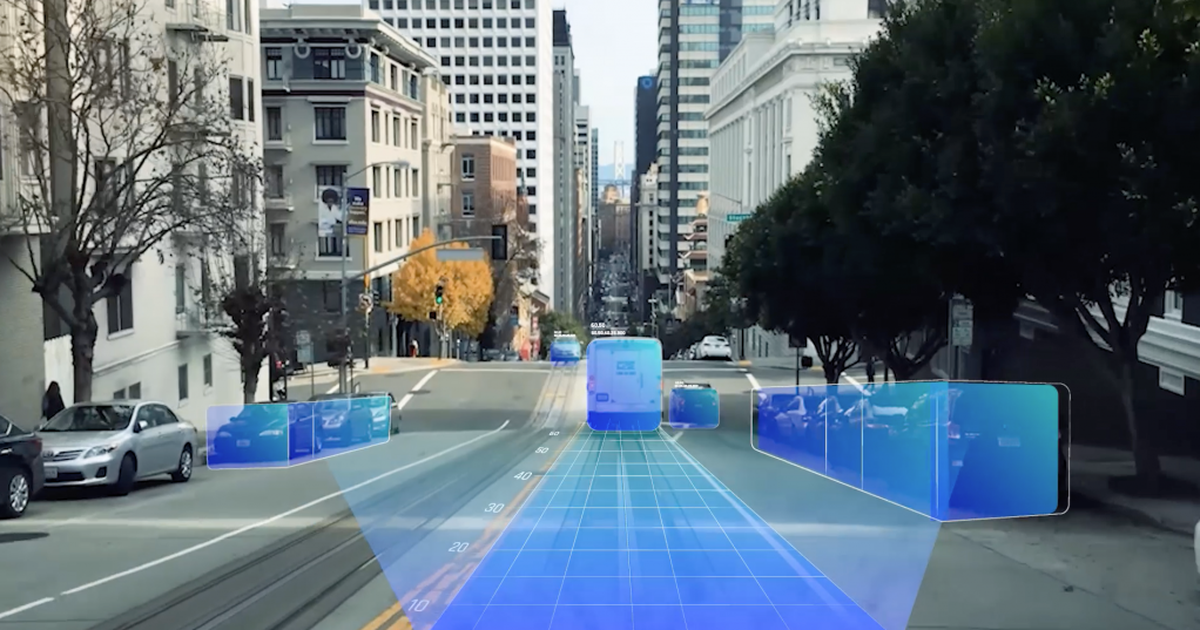
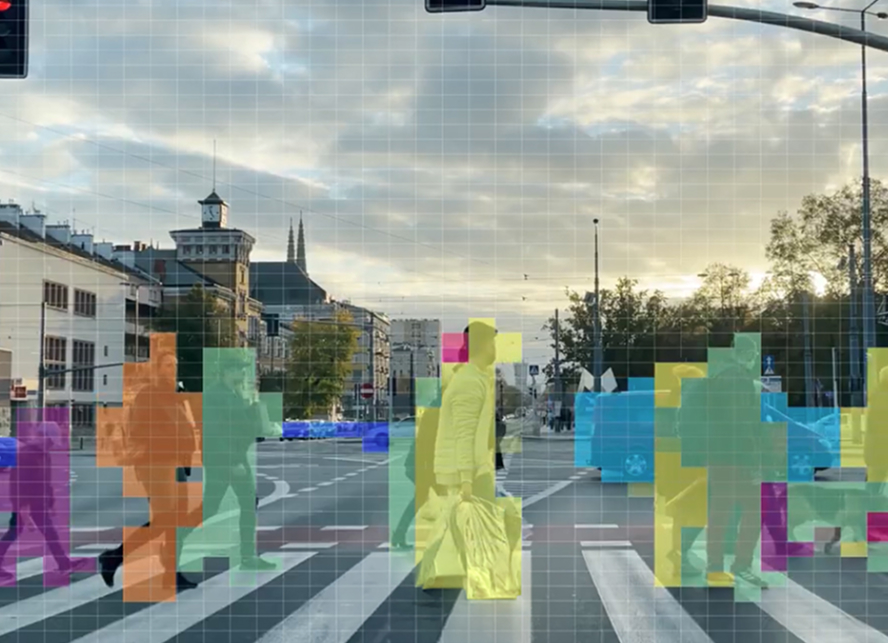
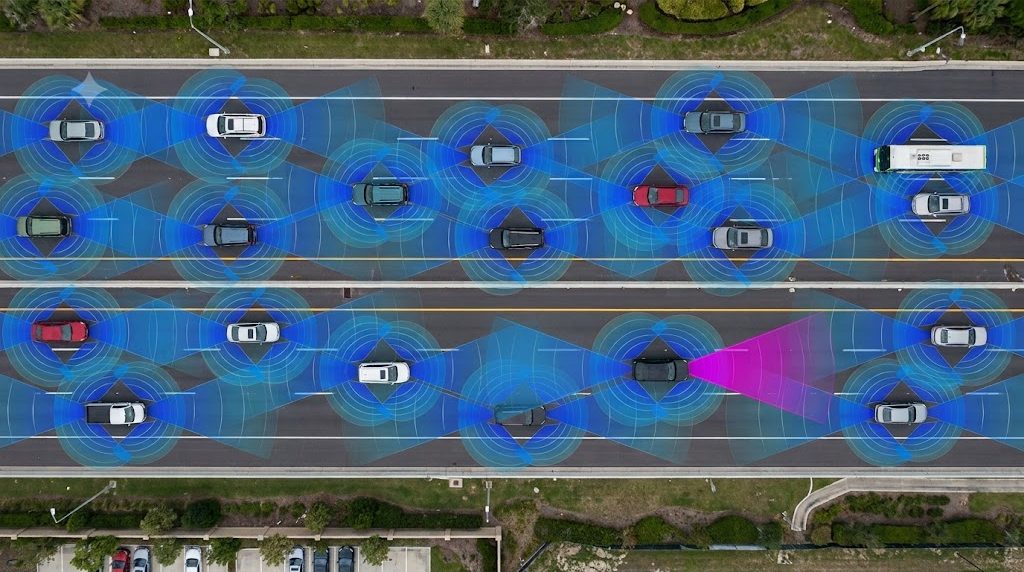
Radar becomes a perception sensor when its output is detailed enough for the vehicle to understand a scene, not just notice that something is in it. A detection radar reports that an object exists at a given range and speed. A perception radar resolves the scene: it separates objects that sit close together, shows their shape and extent, distinguishes a stalled car from a bridge overhead, and maps where the vehicle can safely drive.
Three things make that shift possible: enough resolution to separate objects in both azimuth and elevation, enough processing to handle the resulting raw data in real time, and output that perception software can use directly.
Conventional automotive radar was built for features like adaptive cruise control and emergency braking. It is very good at measuring range and relative speed, and it works in rain, fog, darkness, and glare. But with a small number of channels, its angular resolution is limited. Two objects close together can merge into one return. A stationary object on the road can look a lot like a manhole cover or an overhead sign. Systems compensate by filtering aggressively, which means some real objects get ignored.
That trade-off is acceptable when a driver is watching the road. It is not acceptable when the system is responsible for driving.
A perception-grade radar changes the trade-off by increasing detail. More channels form a larger virtual array, which narrows the angle each measurement covers. The radar can then:
Arbe’s Phoenix radar system uses 2,304 virtual channels built from Arbe’s own RF transmitter and receiver chips. Its angular resolution is 0.7 degrees in azimuth and 0.9 degrees in elevation, with a 120 by 30 degree field of view and a detection range beyond 300 meters
High channel count produces a lot of raw data. To turn that data into perception, the radar has to process it in real time, at production scale, within automotive power and cost limits. Arbe developed a dedicated high-definition radar processing chip for this job
The last step is output format. Arbe’s AI algorithms convert radar data into a perception-ready layer, of a highly detailed point cloud. OEM and autonomy teams can feed this layer straight into their perception stacks instead of building radar interpretation from scratch.
An autonomous system’s operational design domain (ODD) defines the conditions it is designed to handle: road types, speeds, weather, and lighting. Each sensor limits that domain in its own way. Cameras struggle in low light, glare, and heavy precipitation. Lidar performance can degrade in fog, heavy rain, and snow. Radar is the sensor least affected by weather and lighting.
When radar can only detect, it acts as a backup that confirms what other sensors report. When radar can perceive, it can carry more of the load when other sensors are impaired. That is the case where radar can help a system stay available in more of the conditions drivers actually face, instead of handing control back.
In eyes-off driving, false alarms are a trust problem as much as an engineering one. Phantom braking and unnecessary handovers teach drivers that the system cannot be relied on. Higher resolution helps because the system has less reason to guess. When it can see that an object is overhead, or that two returns are separate objects, it can filter less aggressively and react to the right things.
Connect to learn more